 |
GranOO 3.0
A robust and versatile workbench to build 3D dynamic simulations based on the Discrete Element Method
|
Loading...
Searching...
No Matches
|
GranOO 3.0
A robust and versatile workbench to build 3D dynamic simulations based on the Discrete Element Method
|
a base class that represents an element More...
#include <Element.hpp>
Public Member Functions | |
| Element (Shape::Volume &shape, const Geom::Point &point) | |
| constructor | |
| Element (Shape::Volume &shape) | |
| constructor | |
| virtual | ~Element ()=0 |
| destructor | |
| virtual std::string | shape_class_ID () const =0 |
| get the related shape classID | |
| void | add_bond (Bond &b) |
| add a bond to the _bondset list | |
| void | erase_bond (Bond &b) |
| erase a bond from the _bondset list | |
| bool | is_bonded (const Element &el) const |
| ask if the current element is bonded to another one | |
| bool | is_bonded (const Element &el, Bond *&commonBond) |
| ask if the current element is bonded to another one | |
| bool | is_bonded (const Element &el, const Bond *&commonBond) const |
| similar as is_bonded(const Element& el, Bond*& commonBond), given for convenience | |
| bool | is_bonded (const Bond &bond) const |
ask if the current element is bonded to bond | |
| Bond & | common_bond (const Element &el) |
returns the bond that bonds the current element with the el element | |
| const Bond & | common_bond (const Element &el) const |
| void | delete_all_bond () |
| delete all the bond connected to the current element | |
| Core::SetOfBase< Bond > & | get_bond_set () |
| get the bond list of the current element | |
| size_t | get_bond_number () const |
| get the number of bond connected to the current element | |
| Core::SetOfBase< Element > | get_bonded_element () |
| get a list of bonded element | |
| bool | is_unbonded () const |
| util method to know if the current element is unbonded | |
| bool | is_bonded () const |
| util method to know if the current element is bonded | |
| double | compute_kinetic_energy () const |
| compute the kinetic energy of the current element | |
| void | compute_bond_cluster (Core::SetOfBase< DEM::Element > &cluster_set, Core::SetOfBase< DEM::Bond > &parsed_bond) |
| util method for detecting a cluster | |
| virtual std::string | info () const |
| get some info on a given element | |
| NeighbourManager< Element > & | neighbour () |
| get a list of neighbour element | |
| const NeighbourManager< Element > & | neighbour () const |
| same as Element::neighbour(), provided for convenience | |
| Core::SetOfBase< Element > & | neighbour_set () |
| get a list of neighbour element | |
| const Core::SetOfBase< Element > & | neighbour_set () const |
| same as neighbour_set(), provided for convenience | |
| void | make_equal_to (const Element &el) |
| for equalizing two elements | |
| virtual std::ostream & | write_ascii (std::ostream &os) const |
| dump the current state of the element in a ascii file (standard *.lgdd format) | |
| virtual std::istream & | read_ascii (std::istream &is) |
| update the current state of the element from an ascii file format *.lgdd | |
| virtual bool | is_spherical_element () const =0 |
| util method for knowing if the element is spherical or not | |
| virtual bool | is_polyhedral_element () const =0 |
| util method for knowing if the element is polyhedral or not | |
| Public Member Functions inherited from GranOO3::Physic::Body | |
| Body (Shape::Volume &shape, const Geom::Point &p, const Geom::Quaternion &q, double mass, const Geom::Tensor &inertia) | |
| constructor | |
| Body (Shape::Volume &shape, const Geom::Point &p) | |
| constructor | |
| Body (Shape::Volume &shape) | |
| constructor | |
| virtual | ~Body ()=0 |
| destructor | |
| void | set_inertia_tensor (const Geom::Tensor &inertia) |
| set the inertia tensor value | |
| void | set_density (double density) |
| set the density value | |
| Geom::Vector | compute_torque_at (const Geom::Point &A) const |
| double | get_kinetic_energy () const |
| double | get_mass () const |
| get the current mass value of the body | |
| void | apply_force_at (const Geom::Vector &, const Geom::Point &) |
| const Shape::Volume & | to_volume_shape () const |
| cast the current object to Shape::Volume | |
| Shape::Volume & | to_volume_shape () |
| cast the current object to Shape::Volume | |
| double | get_volume () const |
| get the current volume of the body | |
| double | get_bounding_radius () const |
| get the current bounding radius of the body | |
| AABB | aabb () const |
| get the aabb tree the body | |
| bool | collide (const Body &other, Collision::Data &col) |
| collision detection with another body | |
| bool | collide (const Body &other) |
| collision detection with another body | |
| void | make_equal_to (const Body &other) |
| for equalizing two bodies | |
| virtual std::ostream & | export_to_povray (std::ostream &out) const |
| exporting to povray format | |
| Public Member Functions inherited from GranOO3::Physic::Node | |
| Node (const Geom::Vector &position) | |
| Node (const Geom::Point &position) | |
| Node () | |
| virtual | ~Node () |
| void | clear_force () |
| void | clear_torque () |
| const Geom::Frame & | local_frame () const |
| void | incremental_move (const Geom::Vector &vec) |
| void | incremental_unmove (const Geom::Vector &vec) |
| void | update_position_from_displacement () |
| void | update_displacement_from_position () |
| void | set_displacement (const Geom::Vector &) |
| void | clear_displacement () |
| void | set_displacement_x (const double &) |
| void | set_displacement_y (const double &) |
| void | set_displacement_z (const double &) |
| void | set_position (const Geom::Vector &) |
| void | set_position_x (const double &) |
| void | set_position_y (const double &) |
| void | set_position_z (const double &) |
| void | set_center (const Geom::Point &) |
| void | update_initial_parameter_to_current_parameter () |
| void | update_from_fem () |
| void | update_from_dem () |
| void | add_interaction (Node &) |
| void | erase_interaction (Node &) |
| bool | interact_with (const Node &) const |
| bool | interact_with (const Ground &) const |
| bool | interact_with (const FEM::Surface &) const |
| void | apply_force (const Geom::Vector &) |
| void | apply_torque (const Geom::Vector &) |
| void | set_quaternion_velocity_from_angular_velocity (const Geom::Vector &angularVelocity) |
| void | set_quaternion_acceleration_from_angular_acceleration (const Geom::Vector &angularAcceleration, const Geom::Vector &angularVelocity) |
| void | update_angular_velocity () |
| virtual void | clear_kinematic () |
| Geom::Vector | get_linear_velocity_at (const Geom::Point &) const |
| void | make_equal_to (const Node &) |
| virtual void | draw () |
| Public Member Functions inherited from GranOO3::Core::Base | |
| virtual | ~Base () |
| size_t | numID () const |
| size_t | uID () const |
| void | set_numID (size_t val) |
| void | clear_numID () |
| Physic::Material & | get_mat () const |
| void | set_mat (Physic::Material *) |
| Base & | item () |
| const Base & | item () const |
| bool | is_same (const Base &) const |
| template<class T> | |
| T & | cast_to () |
| template<class T> | |
| const T & | cast_to () const |
| template<class T> | |
| bool | is () const |
| virtual bool | is (size_t) const |
| virtual const std::string & | get_ID () const |
| virtual Base & | clone () |
| template<class T> | |
| T & | clone_to () |
| Signal< Base & > & | deleted_signal () |
| Public Member Functions inherited from GranOO3::Core::Null | |
| Null () | |
| virtual | ~Null () |
| Public Member Functions inherited from GranOO3::Core::Drawable | |
| Drawable () | |
| virtual | ~Drawable () |
| virtual void | draw_edge () |
| virtual void | init_default_color () |
| virtual std::ostream & | get_info (std::ostream &os) const |
| virtual const Color & | default_color () const |
| Color & | get_color () |
| const Color & | get_color () const |
| virtual void | set_color (const Color &) |
| virtual void | set_alpha (float alpha) |
| void | apply_color () const |
| void | apply_edge_color () const |
| void | apply_default_color () |
| void | apply_selected_color () |
| void | set_line_width (float) |
| float | get_line_width () const |
| float & | get_line_width () |
| void | apply_line_width () const |
| bool | is_visible () const |
| void | set_visible (bool) |
| void | paint () |
| void | paint_edge () |
| unsigned int | get_item_glkey () const |
| Public Member Functions inherited from GranOO3::Core::Register< Base > | |
| Register () | |
| virtual | ~Register () |
| void | erase_from_all_setof () |
| bool | belong_to_setof (const std::string &setOfId) const |
| std::list< SetOf< Base > * > & | get_setof_list () |
| unsigned long long int | get_numeric_ID () const |
| Public Member Functions inherited from GranOO3::Core::PropClass< Node > | |
| PropClass () | |
| virtual | ~PropClass () |
| T & | new_object () |
| T & | get () |
| bool | prop_exist () const |
| void | add_prop (Core::Prop< Node > *) |
| void | remove_prop (Core::Prop< Node > *) |
| std::string | info () const |
| Public Member Functions inherited from GranOO3::Core::Register< Node > | |
| Register () | |
| virtual | ~Register () |
| void | erase_from_all_setof () |
| bool | belong_to_setof (const std::string &setOfId) const |
| std::list< SetOf< Node > * > & | get_setof_list () |
| unsigned long long int | get_numeric_ID () const |
| Public Member Functions inherited from GranOO3::Core::PropClass< Body > | |
| PropClass () | |
| virtual | ~PropClass () |
| T & | new_object () |
| T & | get () |
| bool | prop_exist () const |
| void | add_prop (Core::Prop< Body > *) |
| void | remove_prop (Core::Prop< Body > *) |
| std::string | info () const |
| Public Member Functions inherited from GranOO3::Core::Register< Body > | |
| Register () | |
| virtual | ~Register () |
| void | erase_from_all_setof () |
| bool | belong_to_setof (const std::string &setOfId) const |
| std::list< SetOf< Body > * > & | get_setof_list () |
| unsigned long long int | get_numeric_ID () const |
| Public Member Functions inherited from GranOO3::Core::PropClass< Element > | |
| PropClass () | |
| virtual | ~PropClass () |
| T & | new_object () |
| T & | get () |
| bool | prop_exist () const |
| void | add_prop (Core::Prop< Element > *) |
| void | remove_prop (Core::Prop< Element > *) |
| std::string | info () const |
| Public Member Functions inherited from GranOO3::Core::Register< Element > | |
| Register () | |
| virtual | ~Register () |
| void | erase_from_all_setof () |
| bool | belong_to_setof (const std::string &setOfId) const |
| std::list< SetOf< Element > * > & | get_setof_list () |
| unsigned long long int | get_numeric_ID () const |
Static Public Member Functions | |
| static Element * | new_object (const TiXmlElement *el) |
| instantiate a new element from an XML input file | |
| Static Public Member Functions inherited from GranOO3::Core::Base | |
| static Base & | get_by_numID (size_t) |
| static void | clear_all_numID () |
| static unsigned int | get_sub_class_number () |
| Static Public Member Functions inherited from GranOO3::Core::Drawable | |
| static Drawable & | get_drawable_item_by_glkey (int) |
| static void | set_draw_precision (unsigned int p) |
| static void | increase_draw_precision () |
| static void | decrease_draw_precision () |
| static unsigned int | get_draw_precision () |
Protected Attributes | |
| Core::SetOfBase< Bond > | _bondset |
| the always up-to-date list of bond which are bonded to the current element | |
| NeighbourManager< Element > | _neighbour |
| the always up-to-date list of bond which are bonded to the current element | |
| Protected Attributes inherited from GranOO3::Physic::Body | |
| double | _density |
| the density value of the body | |
| double | _mass |
| the mass value of the body | |
| Geom::Tensor | _inertia_tensor |
| the inertia tensor of the body | |
| Geom::Tensor | _inverse_inertia_tensor |
| the inverse of the inertia tensor of the body | |
| Protected Attributes inherited from GranOO3::Core::PropClass< Node > | |
| std::vector< Core::Prop< Node > * > | _prop |
| Protected Attributes inherited from GranOO3::Core::PropClass< Body > | |
| std::vector< Core::Prop< Body > * > | _prop |
| Protected Attributes inherited from GranOO3::Core::PropClass< Element > | |
| std::vector< Core::Prop< Element > * > | _prop |
Private Member Functions | |
| Element (const Element &)=delete | |
| Element & | operator= (const Element &)=delete |
| template<class Archive> | |
| void | serialize (Archive &, const unsigned int) |
| complete serializing of the element in the *.gdd format | |
Friends | |
| class | boost::serialization::access |
Additional Inherited Members | |
| Static Public Attributes inherited from GranOO3::Core::Null | |
| static Null | null = Null() |
| Protected Member Functions inherited from GranOO3::Core::Base | |
| Base () | |
| Static Protected Member Functions inherited from GranOO3::Core::Base | |
| static unsigned int | affect_class_rank_ID () |
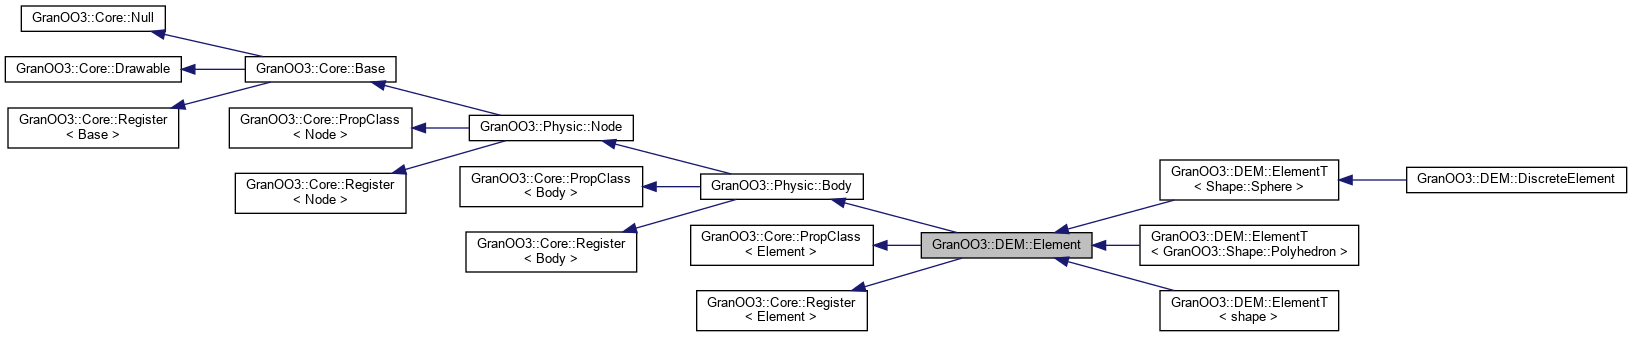
a base class that represents an element
Be aware, an Element has no associated shape, so this is a pure virtual class. A shape is associated to an Element through its child template class ElementT.
Note that, for GranOO, a DiscreteElement is simply a spherical Element.
| GranOO3::DEM::Element::Element | ( | Shape::Volume & | shape, |
| const Geom::Point & | point ) |
constructor
| [in] | shape | : the shape to clone |
| [in] | point | : initial position of the element |
| GranOO3::DEM::Element::Element | ( | Shape::Volume & | shape | ) |
constructor
| [in] | shape | : the shape to clone |
|
pure virtual |
destructor
Note that the destructor send a message to its related DEM::Bond for destructing them
|
privatedelete |
| void GranOO3::DEM::Element::add_bond | ( | Bond & | bond | ) |
add a bond to the _bondset list
| [in] | bond | : the bond to add |
This is a utility method for managing the _bondset list. In addition to the _bondset list, this method add the bonded Element to the _neighbour list
returns the bond that bonds the current element with the el element
| [in] | el | : the element to check |
This is a useful method for extracting a common bond between to element. Note that, if no common bond are detected, this method raises an assertion. So, you have to be sure that the el element is connected to the current one.
| void GranOO3::DEM::Element::compute_bond_cluster | ( | Core::SetOfBase< DEM::Element > & | cluster_set, |
| Core::SetOfBase< DEM::Bond > & | parsed_bond ) |
util method for detecting a cluster
| [out] | cluster_set | : a list of element that represents the cluster of element |
| [out] | parsed_bond | : a list of the bond that was parsed for creating the cluster |
This method can be used for retrieving a cluster of Element. A cluster is is simply a set of Element which are bonded. This method can be used for retrieving pieces of
element that detach from another one. Note that this method requires huge computational time as it use a recursive algorithm for finding cluster.
|
inline |
compute the kinetic energy of the current element
Here, the kinetic energy includes the linear and angular velocity part. Note that the way the kinetic energy is computed for the angular volicity is too simple (it is correct only for spherical element). TODO (we must revise this)
| void GranOO3::DEM::Element::delete_all_bond | ( | ) |
delete all the bond connected to the current element
Note that this method, really delete the bonds by invoking their destructors
| void GranOO3::DEM::Element::erase_bond | ( | Bond & | bond | ) |
erase a bond from the _bondset list
| [in] | bond | : the bond to erase |
This is a utility method for managing the _bondset list. In addition to the _bondset list, this method remove the bonded Element to the _neighbour list
|
inline |
get the number of bond connected to the current element
|
inline |
get the bond list of the current element
Note that this method returns the list in read and write mode. It means that you can modify it. If you modify the list in such way, you must know what you do, because it could lead to unexpected behavior.
| Core::SetOfBase< Element > GranOO3::DEM::Element::get_bonded_element | ( | ) |
get a list of bonded element
As there is no internal way of storing the list of bonded element, this list is built on-the-fly and this method returns a copy of this list. Note that this method induces some computational cost.
|
virtual |
get some info on a given element
Reimplemented from GranOO3::Physic::Body.
Reimplemented in GranOO3::DEM::DiscreteElement, GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
| bool GranOO3::DEM::Element::is_bonded | ( | ) | const |
util method to know if the current element is bonded
true is the the current element isnbonded false otherwiseAn element is considered as bonded if one bond at least is connected to the current element.
| bool GranOO3::DEM::Element::is_bonded | ( | const Bond & | bond | ) | const |
ask if the current element is bonded to bond
| [in] | bond | : the bond to check if it is connected to the current element |
bond one, false otherwiseThis is a useful method for detecting if an element is bonded to a specific Bond.
| bool GranOO3::DEM::Element::is_bonded | ( | const Element & | el | ) | const |
ask if the current element is bonded to another one
| [in] | el | : the another one element |
el one, false otherwiseThis is a useful method for detecting if an element is bonded through a Bond to another one.
ask if the current element is bonded to another one
| [in] | el | : the another one element |
| [out] | commonBond | : a pointer to the common bond (nullptr if it is not bonded) |
el one, false otherwiseThis is a useful method for detecting if an element is bonded through a Bond to another one. If this is the case, this method retrieve the commonBond.
similar as is_bonded(const Element& el, Bond*& commonBond), given for convenience
|
pure virtual |
util method for knowing if the element is polyhedral or not
true if the element is polyhedral, false otherwiseNote that this method is pure virtual because the Element class does not know its real shape
Implemented in GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
|
pure virtual |
util method for knowing if the element is spherical or not
true if the element is spherical, false otherwiseNote that this method is pure virtual because the Element class does not know its real shape
Implemented in GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
| bool GranOO3::DEM::Element::is_unbonded | ( | ) | const |
util method to know if the current element is unbonded
true is the the current element is unbonded false otherwiseAn element is considered as unbonded if no bond is connected to the current element.
| void GranOO3::DEM::Element::make_equal_to | ( | const Element & | el | ) |
for equalizing two elements
| [in] | el | : the element which will be used as a model for equalizing |
This method can be used for equalizing the current element (this) to another one (el). When you equalize two elements, they have the same position, velocity, mass, etc. This method can be used used for cloning elements.
|
inline |
get a list of neighbour element
An element is considered as a neighbour of another one if it is bonded to this element. Note that the neighbour list could potentially be used with contact but this not implemented.
|
inline |
same as Element::neighbour(), provided for convenience
|
inline |
get a list of neighbour element
This method is quite similar to Element::neighbour() The sole difference is that it returns directly a list (SetOfBase) of Element instead of returning a NeighbourManager<Element> object.
|
inline |
same as neighbour_set(), provided for convenience
|
static |
instantiate a new element from an XML input file
| [in] | el | : a pointer to the xml element where the element is described |
This method is mainly used for internal usage
|
virtual |
update the current state of the element from an ascii file format *.lgdd
| [in] | is | : the stream where the data are read |
Reimplemented from GranOO3::Physic::Body.
Reimplemented in GranOO3::DEM::DiscreteElement, GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
|
private |
|
pure virtual |
get the related shape classID
As this method is pure virtual, this method returns the "true" class_ID of the shape ("Sphere", "Cone", etc.)
Implemented in GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
|
virtual |
dump the current state of the element in a ascii file (standard *.lgdd format)
| [in] | os | : the stream where the data will be written |
Reimplemented from GranOO3::Physic::Body.
Reimplemented in GranOO3::DEM::DiscreteElement, GranOO3::DEM::ElementT< shape >, GranOO3::DEM::ElementT< GranOO3::Shape::Polyhedron >, and GranOO3::DEM::ElementT< Shape::Sphere >.
|
friend |
|
protected |
the always up-to-date list of bond which are bonded to the current element
|
protected |
the always up-to-date list of bond which are bonded to the current element
 1.15.0